MSRDM野村, 博士論文 2020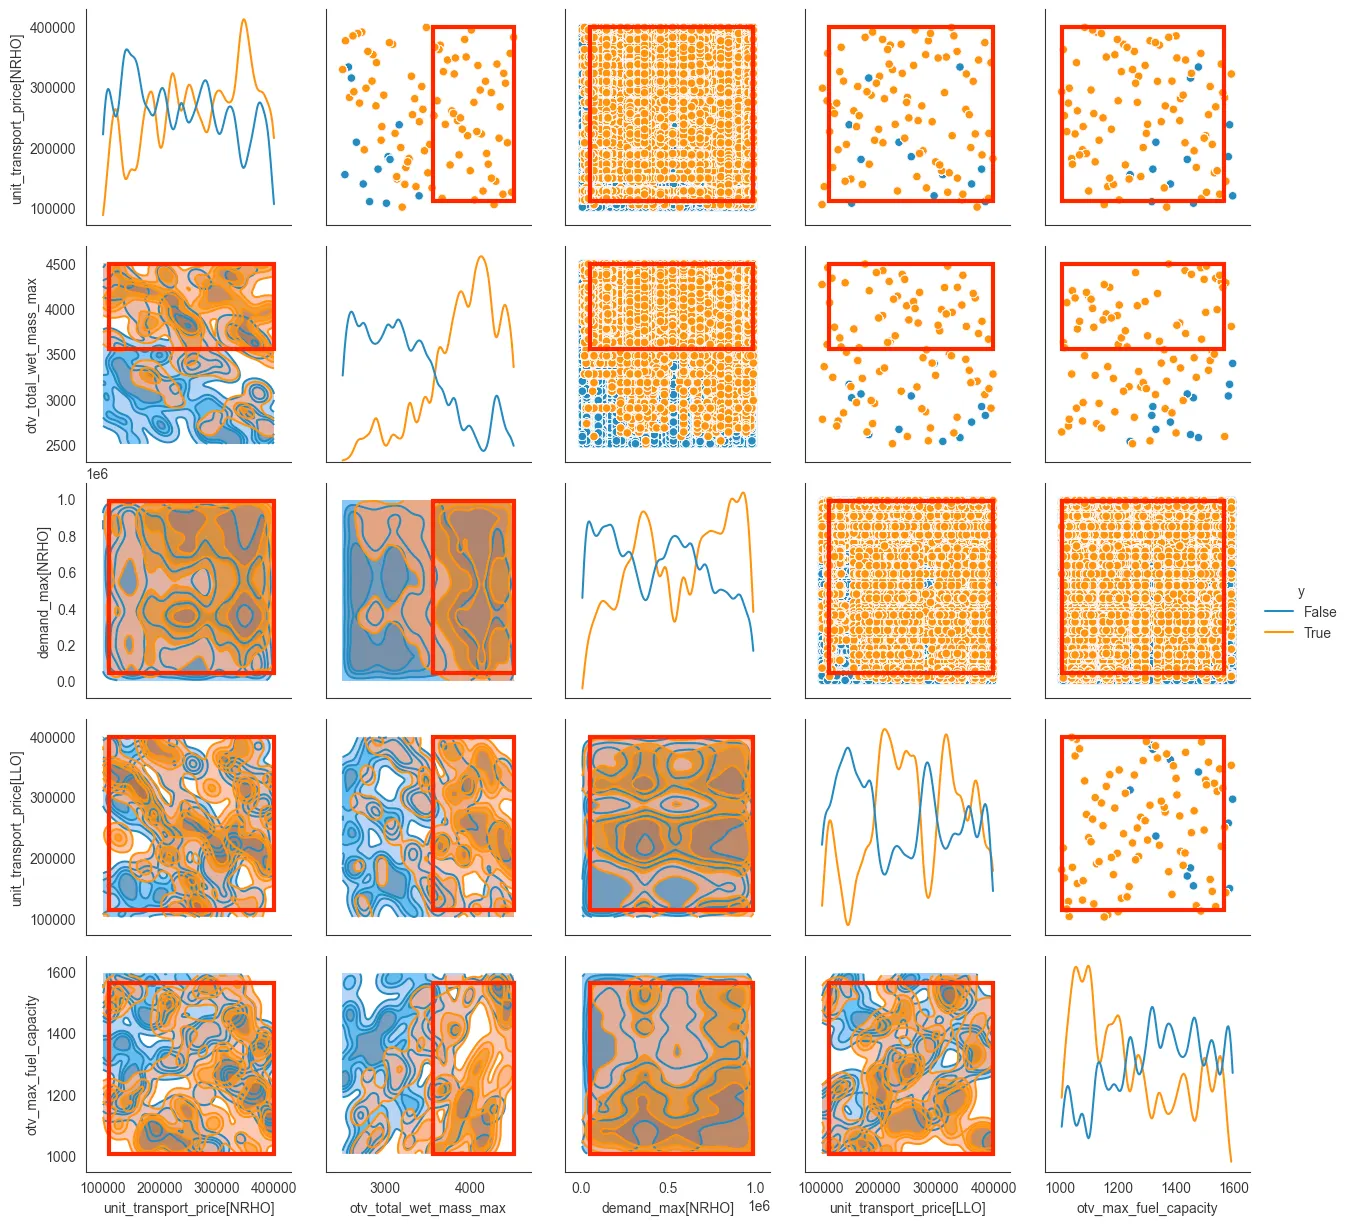 OTV roadmap野村ほか, IAC 2025
Space logistics野村ほか, AIAA SPACE 2018
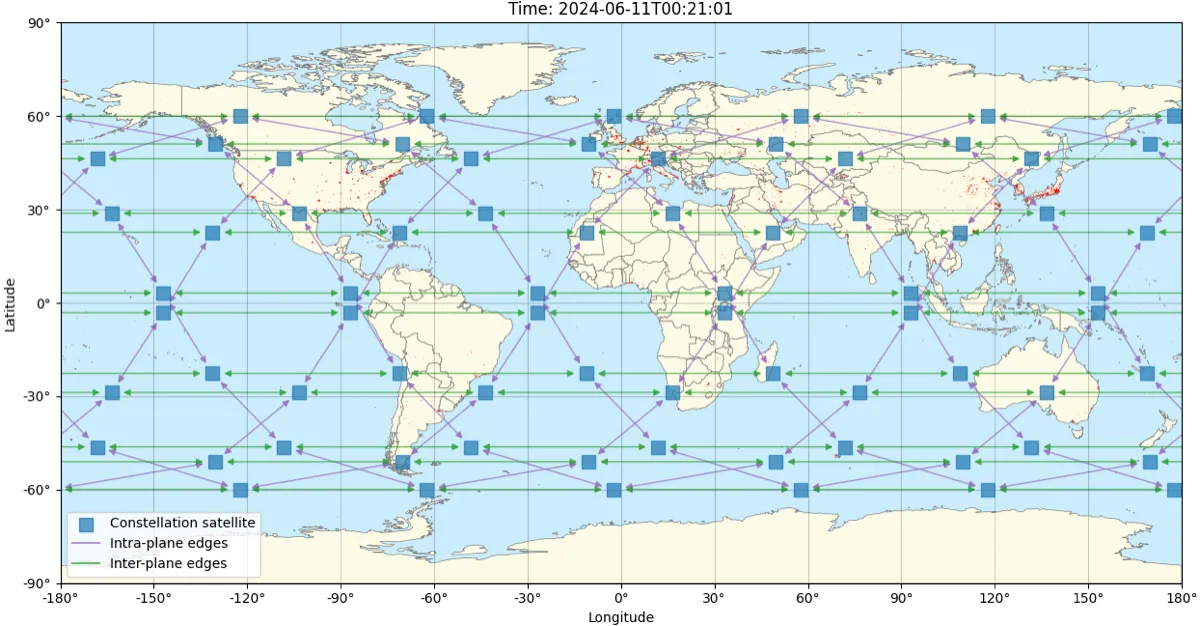 COSMICA
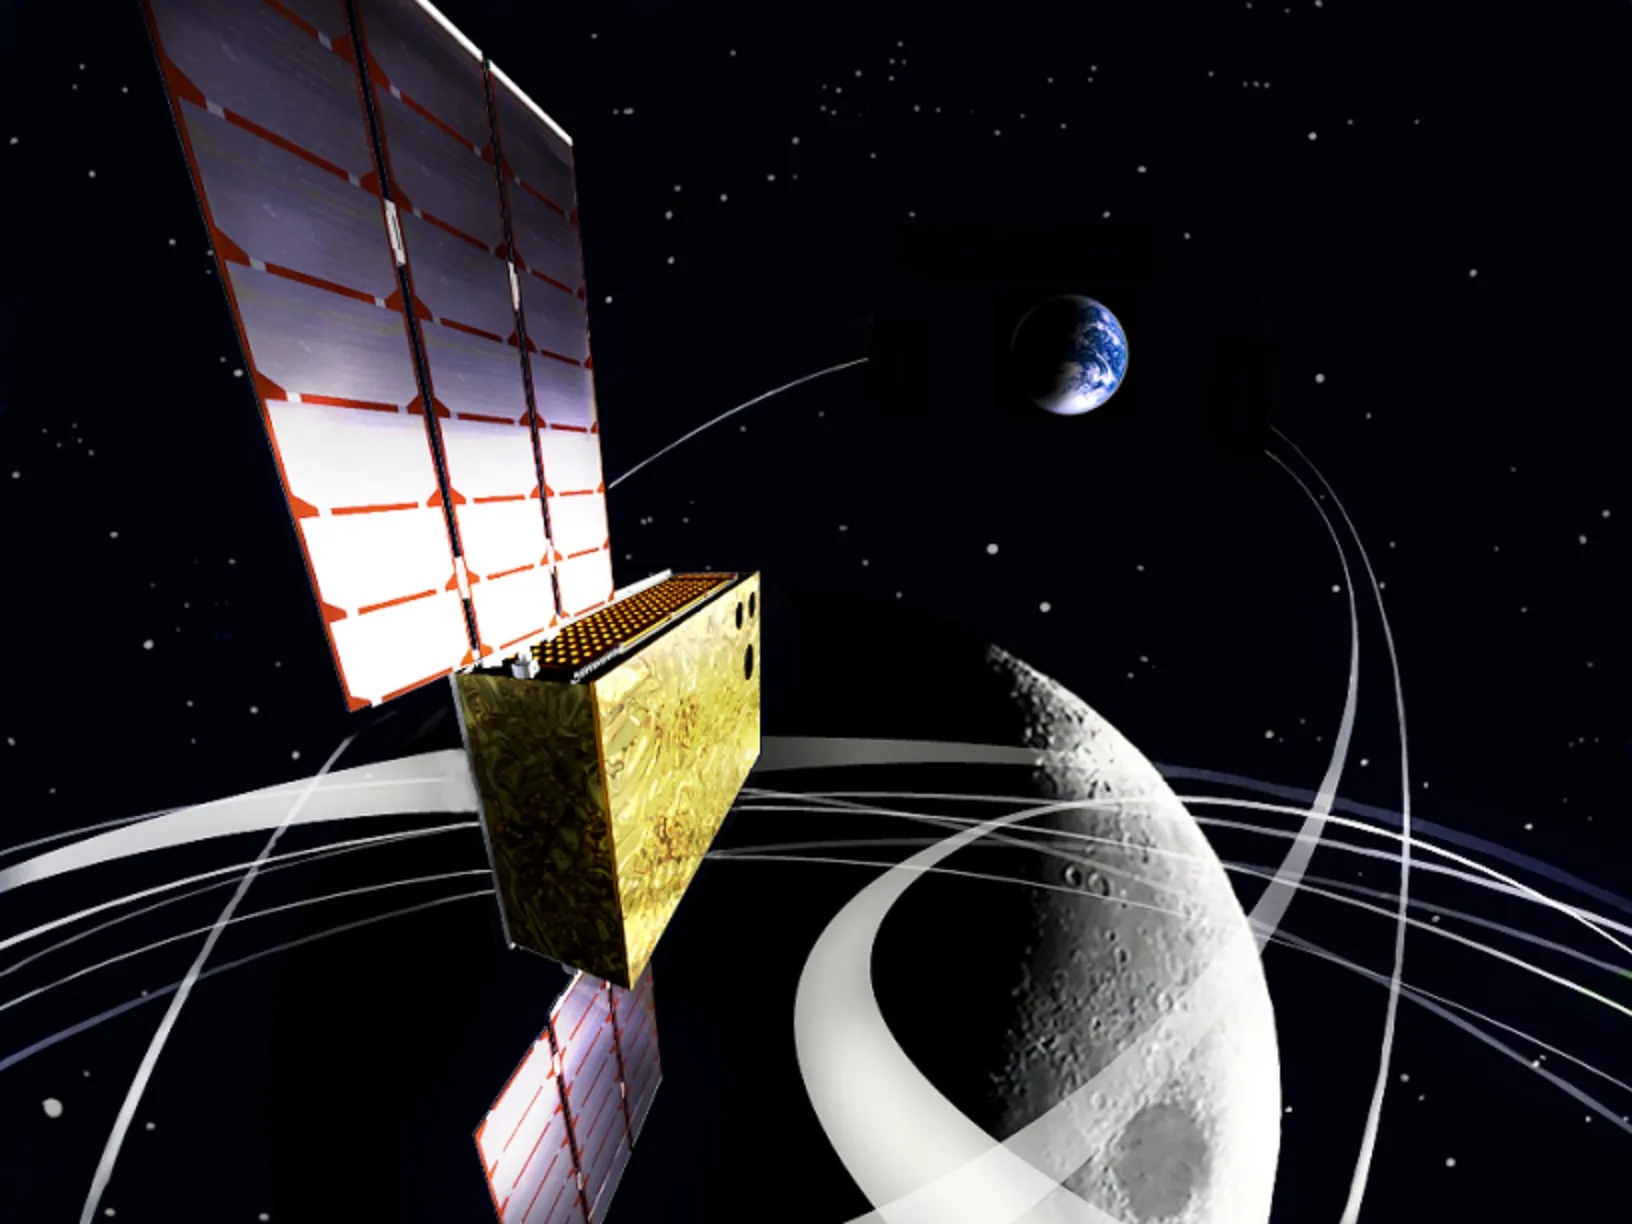 ©EQUULEUS Project Team
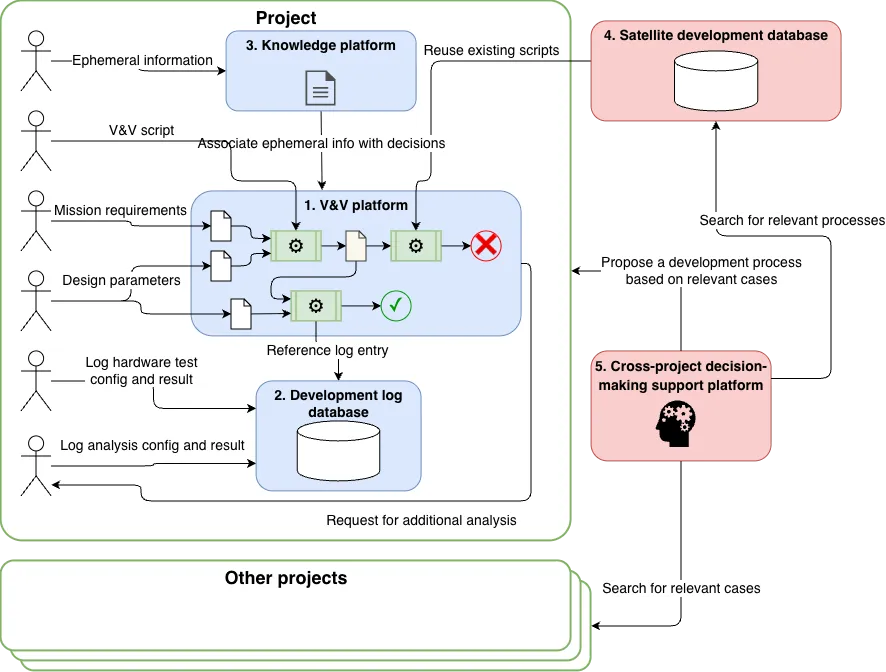 Systems engineering platform野村ほか, 宇科連 2025
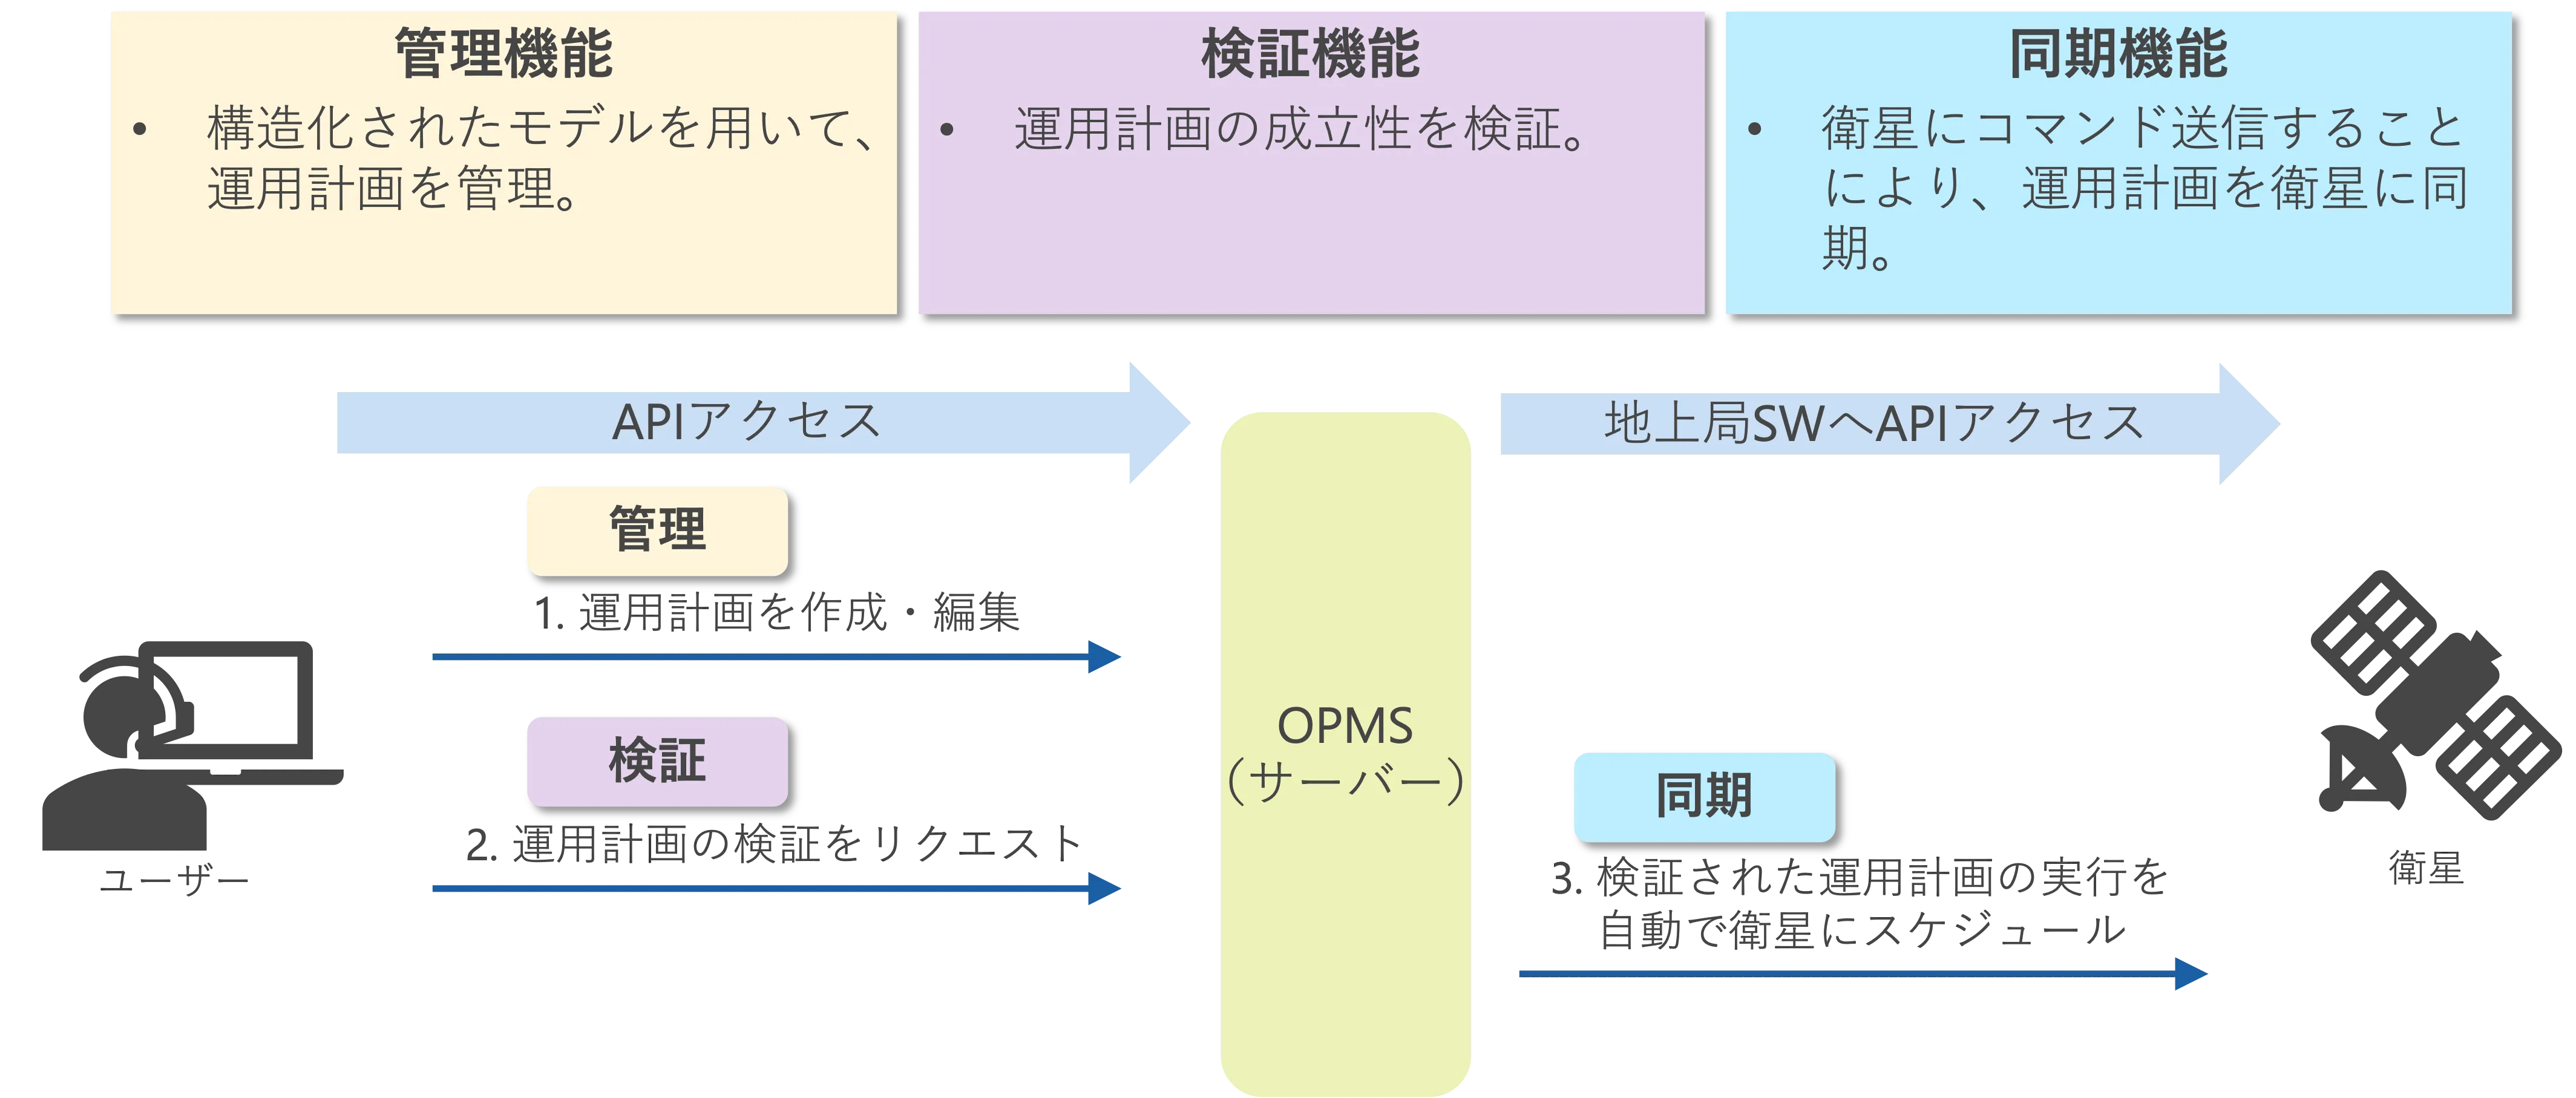 OPMS
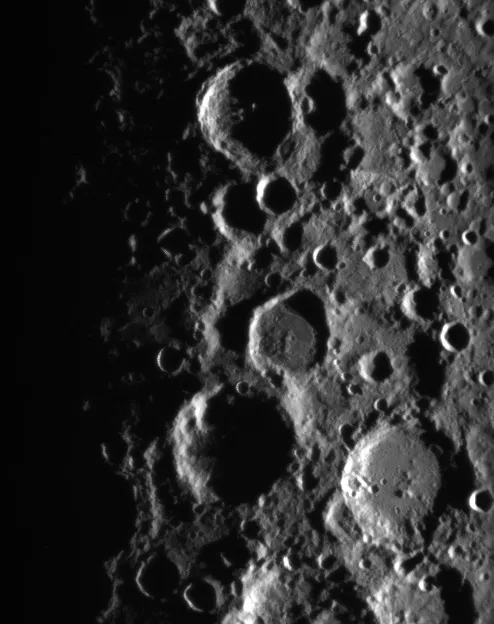 ©EQUULEUS Project Team
param m_dry: Mass = 1200.0 kg;
param m_fuel: Mass = 2800.0 kg;
param isp: Time = 320.0 s;
const node g0: Acceleration =
    9.80665 m/s^2;
node v_e: Velocity = @isp * @g0;
node dv: Velocity = @v_e *
    ln((@m_dry + @m_fuel) / @m_dry);
Graphcal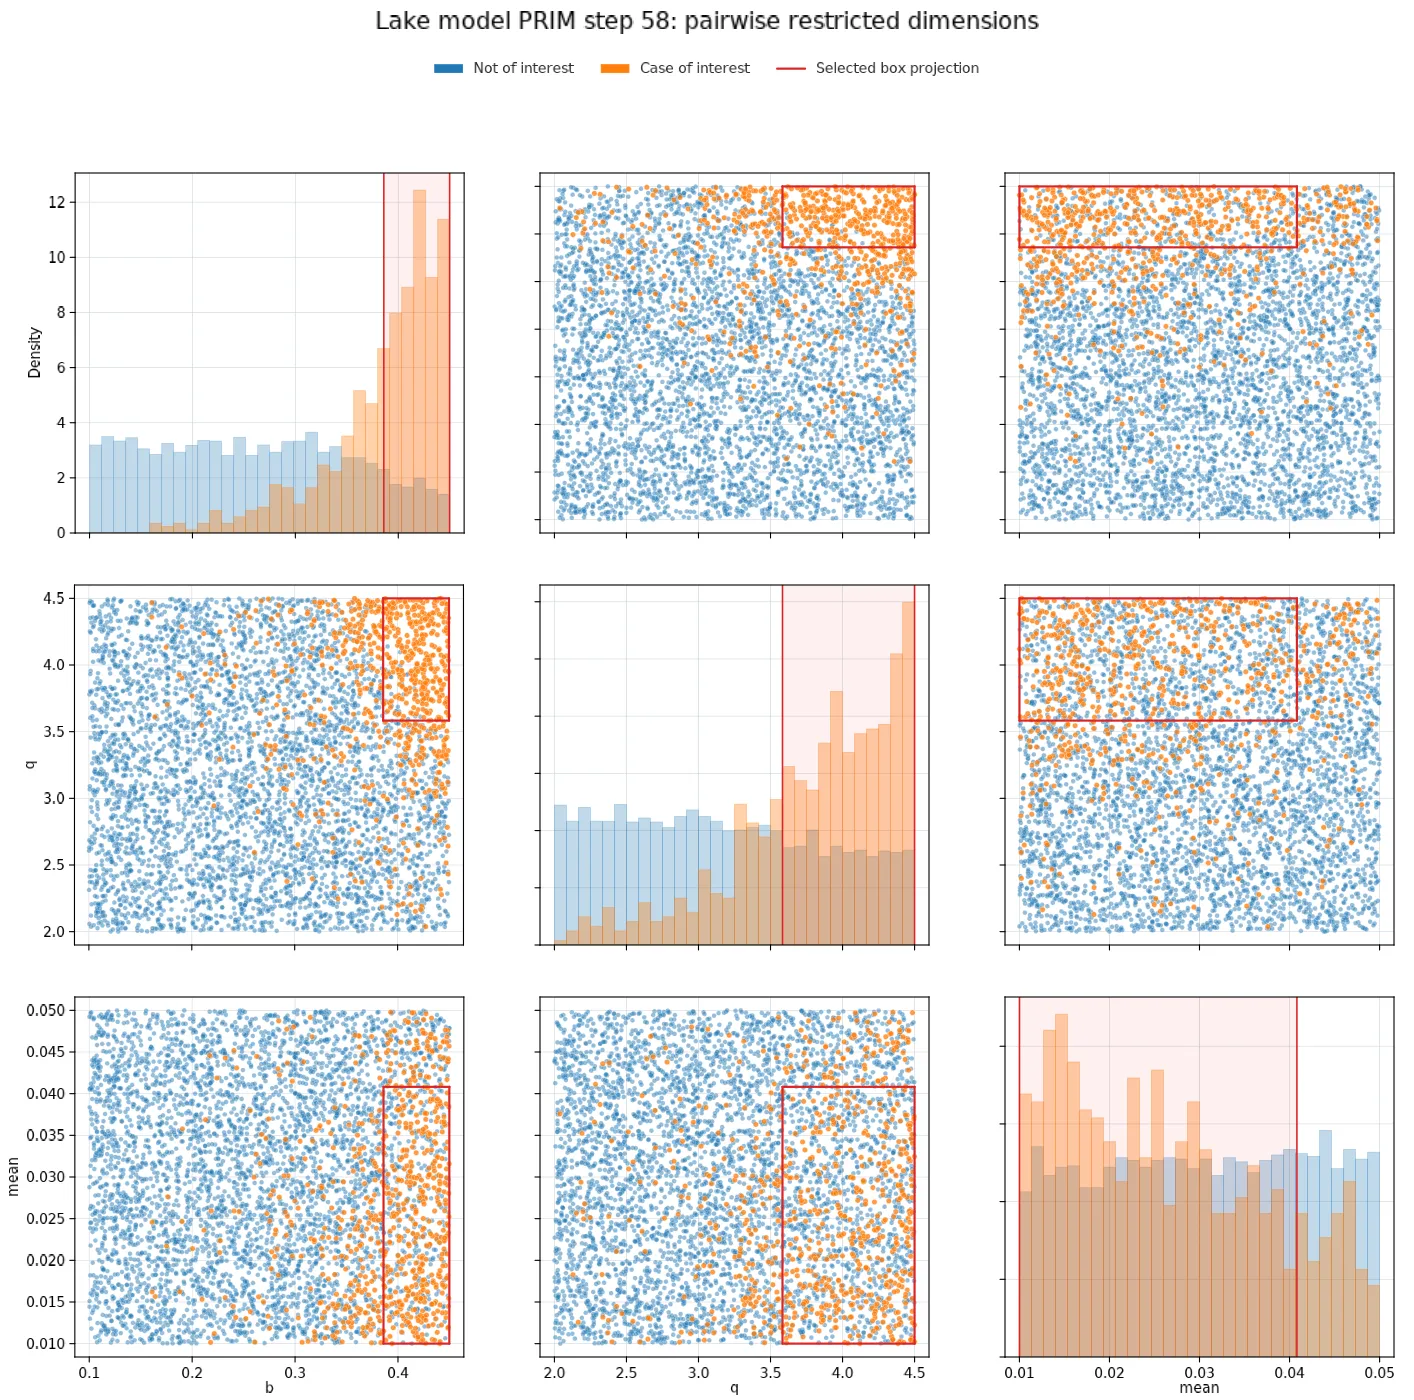 PRIM
Veriq
Capsula
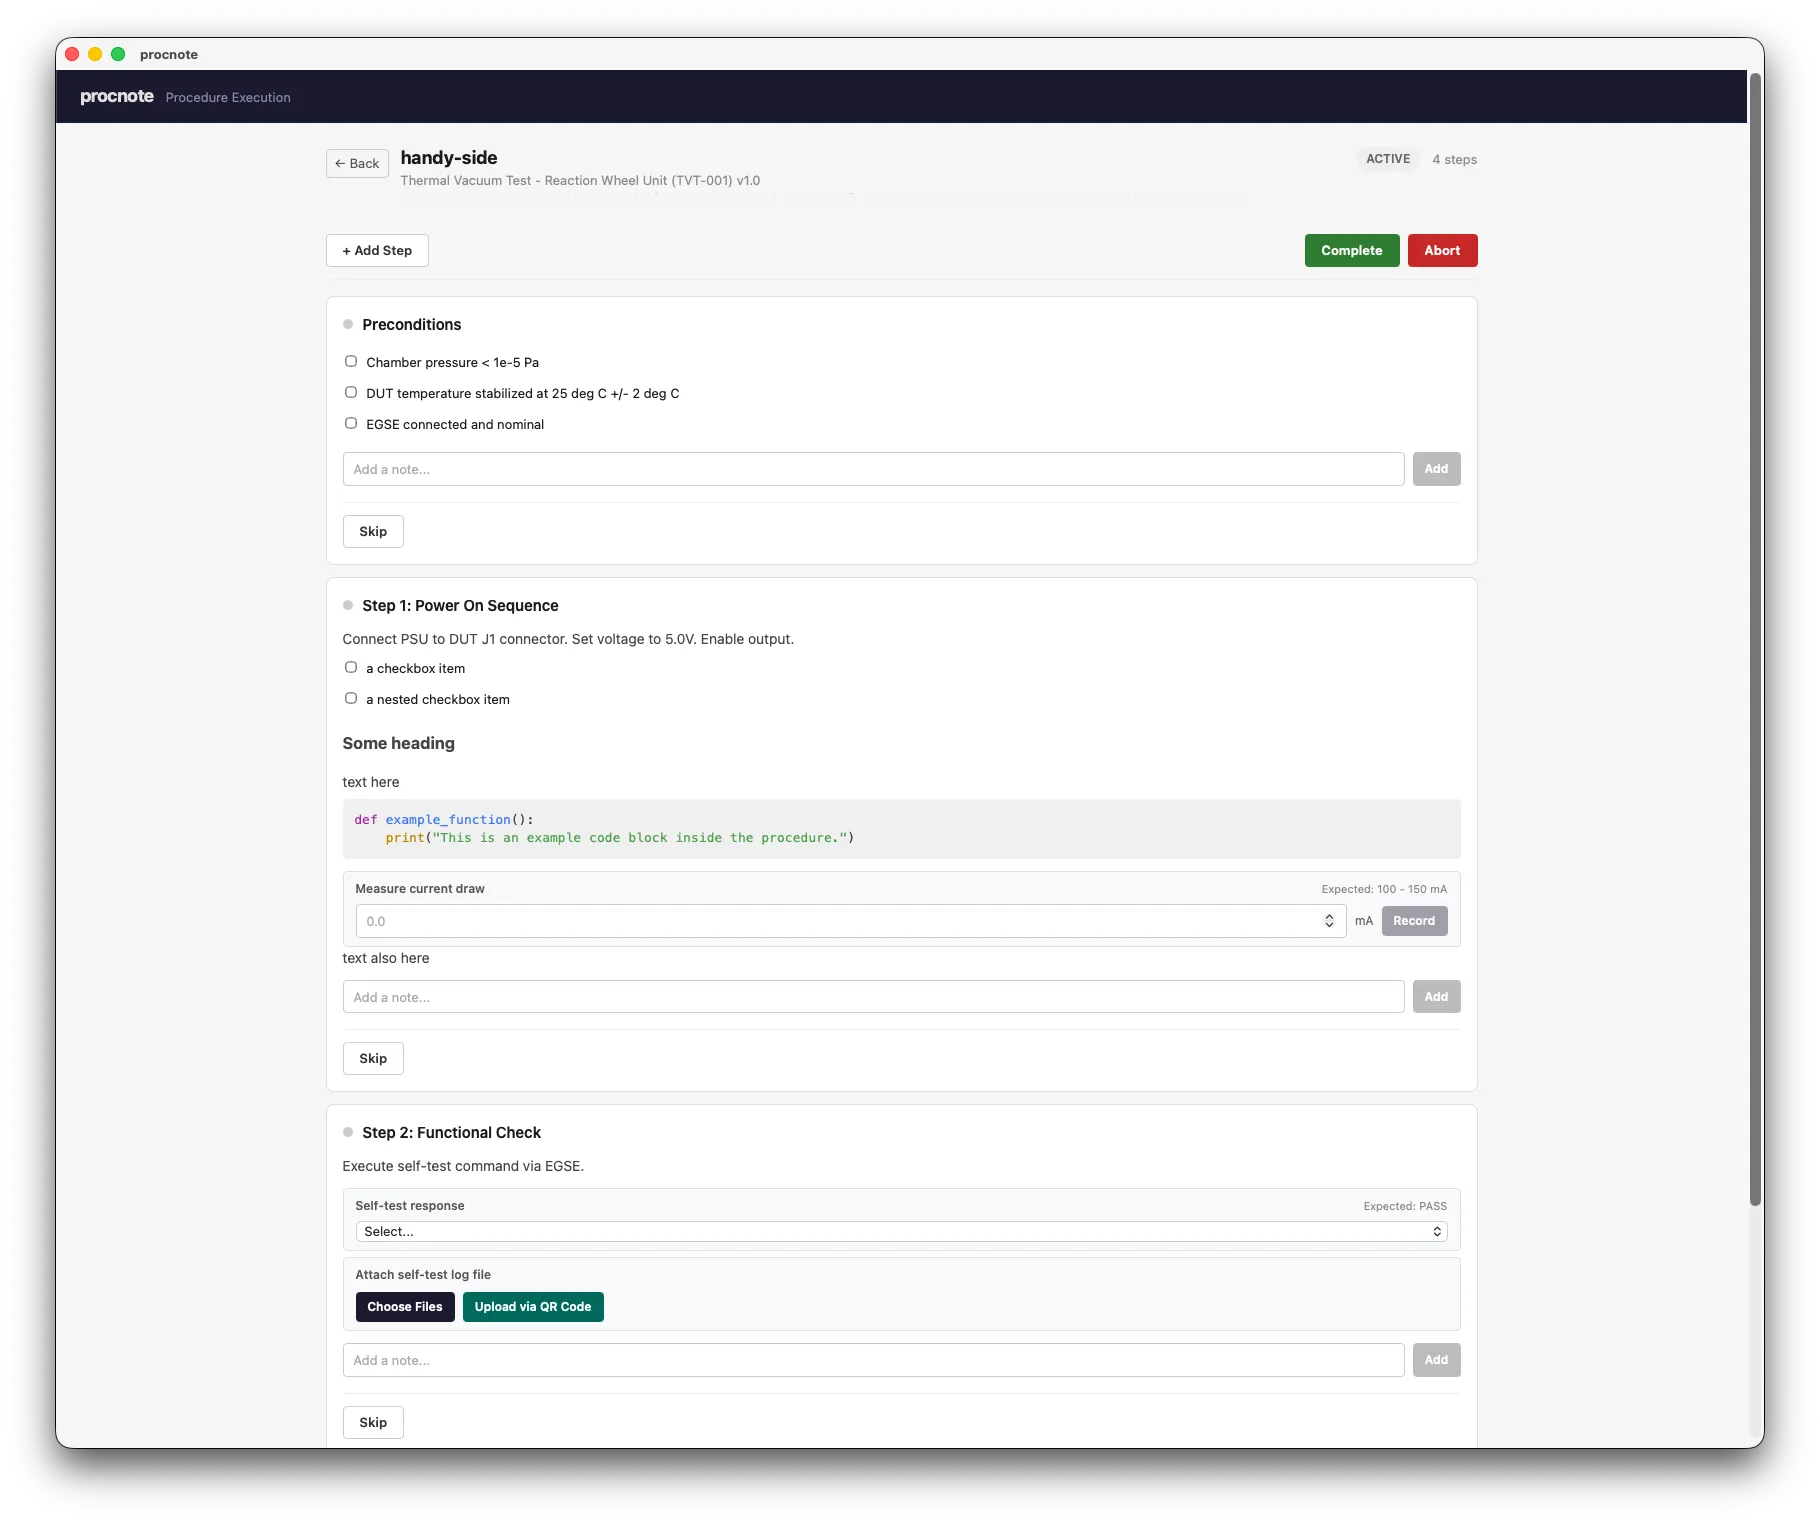 Procnote